
PHD Student of Computer Science
I am a first year PHD student at Shanghai Qi Zhi Institute and VDI, ShanghaiTech University, advised by Prof. Li Yi and Prof. Jiayuan Gu. Previously, I obtained my bachelor’s degress of engineering majored in Artificial Intelligence from South China University of Technology, advised by Prof. Huaidong Zhang.
I am currently interning at Galbot. My research goal is to build human-like visual intelligence systems that could interact with environments as adaptive cognitive agents. My current research focus on perceptive humanoid locomotion and navigation.
- Embodied AI
- Humanoid robot learning
- 3D Computer vision
B.Eng. in Artificial Intelligence
South China University of Technology, 2026
- 2026-09 One paper accepted to IROS 2026.
- 2026-06 One paper accepted to IEEE RA-L (transfer to ICRA 2027).
- 2026-02 One paper accepted to CVPR 2026 Findings.
- 2024-12 I attended the CSIG 2024 conference, deeply grateful for the support of Prof. Huaidong Zhang.
- 2024-07 I was honored to be invited to participate in the YPEC 2024 at City University of Hong Kong, where I had the opportunity to present the poster showcasing our project.
\* indicates equal contribution, † indicates the corresponding author.
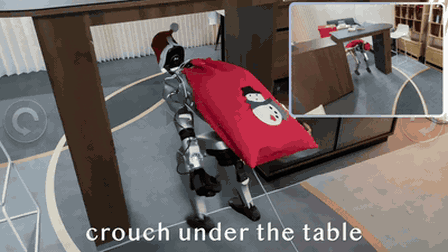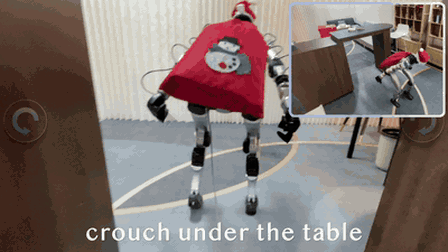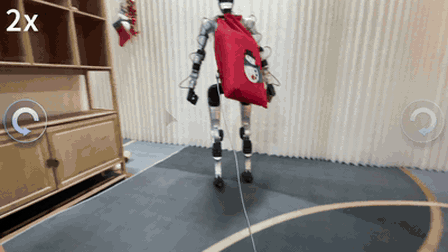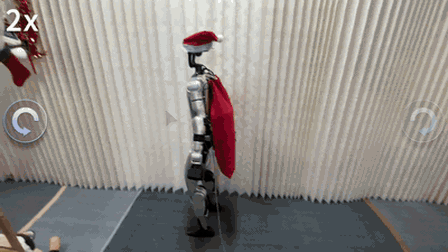
We propose Humanoid Potential Field (HumanoidPF), a representation that tightly bridges environmental perception with whole-body control, enabling humanoids to hurdle, crouch, and squeeze through cluttered indoor scenes, along with a Click-and-Traverse teleoperation system for single-command traversal.
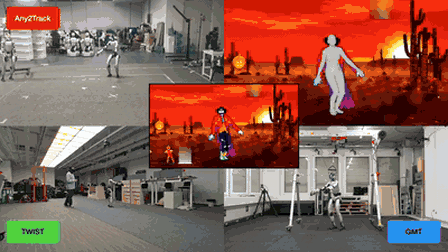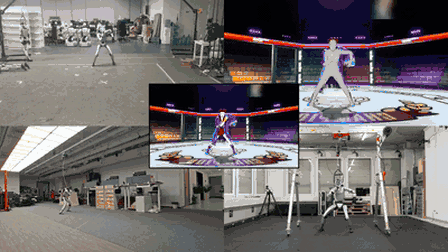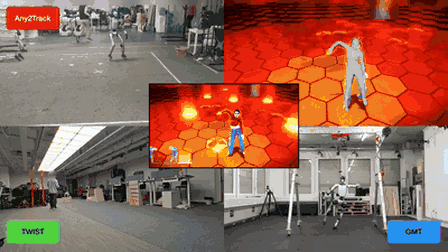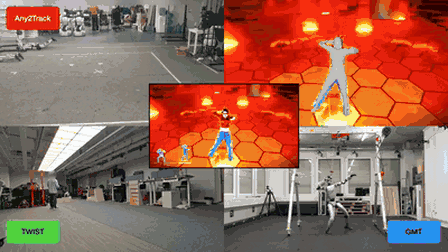
We present Switch-JustDance, a low-cost and reproducible benchmarking pipeline that leverages the motion-sensing console game Just Dance on the Nintendo Switch to evaluate whole-body humanoid motion tracking controllers through the game's built-in scoring system.